A Key Technology Solution for Advancing the Dynamic Response and Power of Next-Generation Robots
In advanced motion applications such as bipedal humanoid robots, quadrupedal robots, and next-generation lightweight collaborative robot arms (cobots), mechanical interference, complex cable routing, and insufficient power-to-weight ratios have long constrained dynamic power and agility. Under the demanding conditions faced by multi-degree-of-freedom joints—including rapid acceleration and deceleration, impact loads during jumps, and precise trajectory tracking—traditional add-on architectures built from separate servo motors, gear reducers, and drive units can no longer meet the extreme integration and lightweight requirements of next-generation robots.
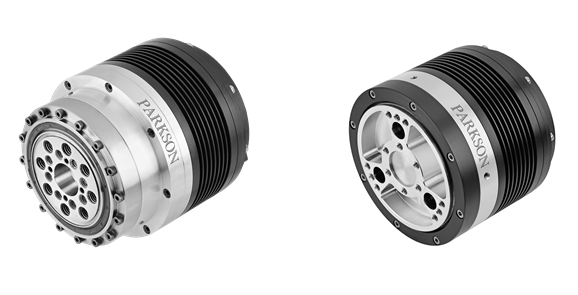
Drawing on deep expertise in mechatronic integration and high-precision servo drives, AXION introduces the JOINT MODULE series of high-performance, three-in-one integrated intelligent joint modules. A high-power-density frameless servo motor, a high-precision planetary or lightweight harmonic reducer, and an intelligent servo drive are tightly integrated in one compact package. The result is a compact joint delivering up to 250 Nm of peak torque—a plug-and-play, high-dynamic-response power core for next-generation robots.
Core Technical Highlights and Architectural Advantages
1. Deep Three-in-One Integration: A More Compact, Lightweight Mechanical Layout
- Eliminates exposed transmission components for an exceptionally compact structure: An inner-rotor frameless servo motor, precision planetary reducer, and high-performance drive control board are integrated into a flat metal housing. This removes conventional adapter flanges, couplings, and complicated external wiring while eliminating mechanical dead space.
- Significantly reduces joint rotational inertia: The flattened, large-bore design shortens the joint axially and reduces its rotational radius, substantially lowering the inertia of the link-end load. This improves instantaneous acceleration, deceleration, and trajectory response across the multi-joint system.
- Plug-and-play modular integration: Standard mechanical flange interfaces support quick installation and removal, reducing the need for complex coaxial alignment and drive tuning. Assembly of a complete machine can be shortened from days to hours, accelerating prototype validation and production integration.
2. Exceptional Torque Density and Instantaneous Power: Ready for Extreme Shock Loads
- 250 Nm peak torque for one second (up to 300% overload): The flagship JJM115-01 delivers 100 Nm of rated torque and up to 250 Nm for a short duration (one second), providing 2.5 times the rated torque for dynamic loads. This gives quadrupeds ample power for running and jumping and humanoids for absorbing landing impacts.
- High-rigidity, impact-resistant planetary gearbox: The gears are vacuum carburized, hardened, and precision ground. Ratios of 20:1 and 25:1 are available. The gearbox maintains low backlash and excellent impact rigidity under heavy, alternating torque from foot strikes and rapid starts and stops.
- High speed and wide speed range: Output speed reaches 80–150 rpm, combining smooth high torque for low-speed, heavy-load movement with the agility and bandwidth required for fast motion.
3. Dual-Encoder Closed-Loop Control and Intelligent Dual-CAN Communications
- Dual 12-bit high-resolution encoders for position feedback: Independent encoders are installed at the motor rotor before the reducer and at the output shaft after the reducer. They compensate in real time for transmission backlash and small mechanical deflections, enabling sub-degree angular repeatability and true closed-loop control at the output.
- Dual-channel CAN bus interface: The built-in high-speed dual CAN bus supports daisy-chain connections, simplifying the connection and wiring of multiple modules and improving system scalability. It also reduces multi-joint backbone wiring and provides strong electromagnetic-interference (EMI) resistance and millisecond-level real-time communications.
- Reliable thermal design for demanding environments: The operating temperature range is -20°C to +60°C, with a storage range of -40°C to +80°C. Optimized thermal paths for critical power modules help maintain thermal stability during outdoor operation, harsh inspection work, and extended high-intensity use.
Product Specifications
| Key Specifications | Unit | JJM115-01 | JJM115-02 | JJM085-01 |
|---|---|---|---|---|
| Rated DC Voltage | VDC | DC 48V | DC 48V | DC 48V |
| Peak Output Torque (1 s) | Nm | 250 | 200 | 150 |
| Continuous Rated Output Torque | Nm | 100 | 80 | 70 |
| Maximum Output Speed | rpm | 158 | 198 | 160 |
| Rated Output Speed | rpm | 120 | 150 | 140 |
| Continuous Rated Phase Current | Arms | 31.8 | 31.8 | 22.3 |
| Peak Phase Current (1 s) | Arms | 95.4 | 95.4 | 66.9 |
| Planetary Gear Ratio | - | 25:1 | 20:1 | 25:1 |
| Position Feedback System | - | Dual 12-bit encoders (closed-loop) | Dual 12-bit encoders (closed-loop) | Dual 12-bit encoders (closed-loop) |
| Communication Interface | - | Dual-channel CAN bus (CAN 2.0) | Dual-channel CAN bus (CAN 2.0) | Dual-channel CAN bus (CAN 2.0) |
| Operating Temperature | °C | -20 to +60 | -20 to +60 | -20 to +60 |
Target Applications
- Quadrupedal robots: Designed for high-impact, high-frequency shoulder, hip, and knee joints, enabling extreme jumps, fast travel over uneven terrain, and rapid dynamic posture stabilization.
- Humanoid robots: Suitable for high-load hip, knee, and ankle joints in the lower limbs and key swinging mechanisms in the upper body, combining impact-resistant power with agile, coordinated human-like gait control.
- Lightweight collaborative robot arms: Supports rapid modular assembly of multi-axis joints for rigid assembly, fast sorting, and precision operations in space-constrained production lines.
- Specialized exoskeletons and mobile platforms: An active-assist unit for medical rehabilitation and industrial load-bearing exoskeletons, and an integrated high-torque steering module for AGVs/AMRs where space is limited.
AXION: Powering Motion. Empowering Innovation.
The AXION JOINT MODULE series combines exceptional power-to-weight ratio, high peak overload capability, and plug-and-play closed-loop control to overcome the mechanical-space and output-power limitations of conventional joints. It is the ideal power core for next-generation biomimetic limbs and advanced automation arms.
PARKSON Industrial Co., Ltd. | Intelligent Manufacturing Without Limits, Creating the Future